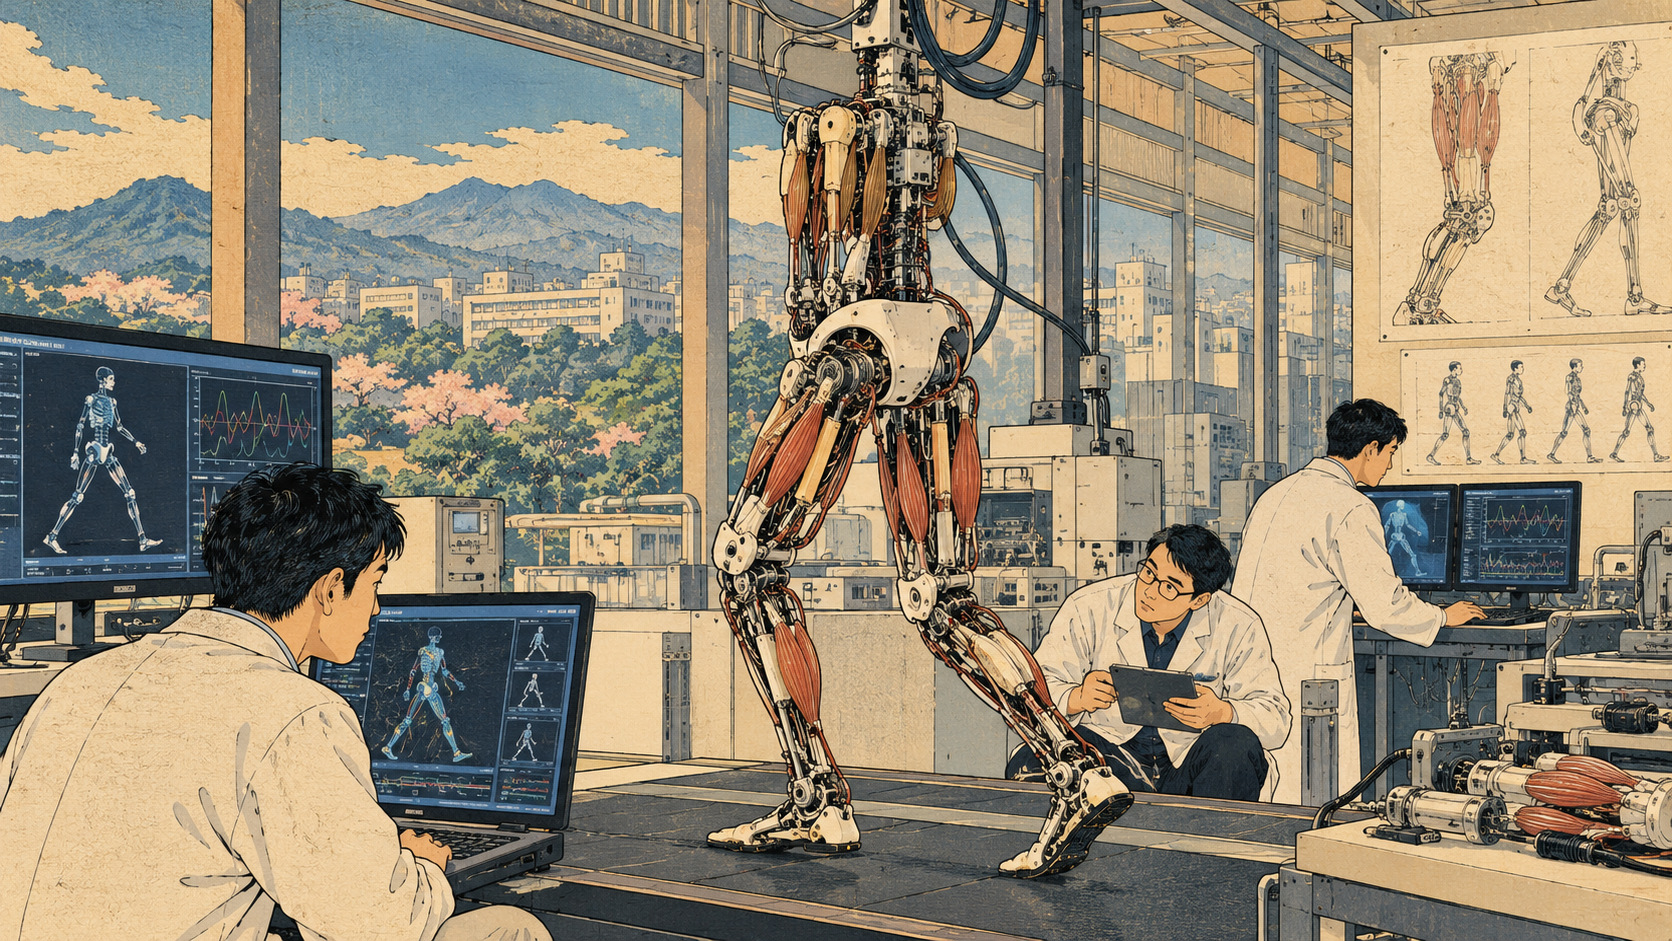
The advance does not remove computers from walking. It gives the robot’s body a bigger share of the work.
What a reflex can teach a robot
Tap the tendon beneath a person's kneecap and the lower leg may kick forward before its owner has consciously chosen to move. This simple clinical test points to an extraordinary capability of living bodies: parts of movement can be regulated locally and rapidly. In research announced on October 22, a Tohoku University team borrowed that idea to build a musculoskeletal robot reflex module. It mimicked a knee-jerk response, then helped generate bipedal walking on a treadmill. The striking part is not that a robot walked. It is where some of the decisions that help it walk now take place: inside the mechanism.
The familiar architecture of robot control
Conventional robotic systems rely on sensors gathering measurements, electronic processing interpreting them and actuators executing commands. Powerful computers can coordinate sophisticated motions, but this architecture can introduce engineering complexity when every small correction must be measured and computed. Researchers have long examined alternatives that exploit the physical properties of bodies, springs and compliant structures. Tohoku's new design takes an especially direct route: it embeds muscle-length feedback in hardware that responds mechanically when stretched beyond a threshold.
The researchers and the published finding
The study was conducted by Shunsuke Koseki, Mitsuhiro Hayashibe and Dai Owaki at Tohoku University's Graduate School of Engineering. The university identifies Hayashibe as a professor and Owaki as an associate professor; Koseki is the corresponding author. Their paper, “Purely Mechanical Muscle Length Feedback Enables Embodied Reflexive Control in Musculoskeletal Robots,” appeared in Advanced Intelligent Systems, with DOI 10.1002/aisy.70590. The university announced the finding on October 22, 2026. The announcement reports experimental demonstrations, not an available commercial product.
A pair of artificial muscles performs two jobs
A key design challenge concerns pneumatic McKibben-type artificial muscles, which shorten when pressurized. In a living muscle, muscle spindles help sense stretch, while muscle fibers produce force. The researchers arranged two artificial muscles in parallel to mimic that division of labor. One acts as the force-producing element; the other plays the sensing role of a muscle spindle. The paired mechanism responds to extension without requiring the sophisticated electronic muscle-length measurement that otherwise complicates such systems.
A reflex that can be adjusted
The module is not merely a spring returning to its original position. By changing pneumatic pressure supplied to the spindle-inspired component, the team can modulate the length threshold at which contraction begins, or switch the reflex behavior on and off. That tunability matters because useful walking requires different responses at different phases of the step. Local mechanical response can coexist with a simpler supervisory system, rather than requiring an all-or-nothing choice between electronics and mechanical intelligence.
From a knee tap to treadmill locomotion
The researchers first reproduced a movement analogous to the patellar tendon reflex. They then assembled a two-legged musculoskeletal platform using four reflex modules per leg. With straightforward control that switches spindle pressure using information from sensors on the soles, the robot was able to walk on a treadmill. This is a specific and meaningful demonstration. It is not evidence of autonomous navigation across a street or a robot able to recover from arbitrary disturbances on rough terrain. Nor was the entire robot electronic-free: the novel local reflex is mechanical, while phase-related control and foot sensing remain in the system.
A history of letting bodies do part of the work
Robotic walking has never followed one single philosophy. Some designs use elaborate models to command each joint. Passive-dynamic walkers have shown that gravity, geometry and mechanical compliance can generate compelling motion with remarkably little actuation. More recently, reinforcement learning has expanded the repertoire of legged machines. Embodied intelligence asks a related question: can the structure and material of the robot take over tasks that would otherwise require computing? Tohoku's result belongs to that conversation, not as a rejection of modern computation but as an attempt to place it where it adds the most value.
Another biological route under study in Sendai
In August 2026, Tohoku researchers including Owaki announced a different effort that drew on walking data from stick insects to develop coordination strategies for a six-legged robot. That work used learning to uncover useful movement rules; the October study instead locates a reflex response in a mechanical assembly. They should not be conflated. Together, they illustrate a broader interest in how animals distribute movement among sensing, the body's physical properties and higher-level control.
The energy claim has a crucial limit
The university argues that shifting some sensing and calculation into a physical mechanism could point toward robots with reduced computational burden and lower power consumption. But the public research summary provides no measured percentage saving against a comparable robot, nor a verified battery-life advantage. A pneumatic muscle system requires energy to generate and regulate pressure. Reducing electronics in one feedback loop is not automatically equivalent to lowering energy consumption of the complete machine. The relevant future comparison will be system-wide and quantitative.
What happens beyond the laboratory
Locomotion on a treadmill is a controlled test. Real-world mobility involves changing surfaces, slopes, steps, unexpected contact, the wear of actuators and reliable operation over many cycles. The module's robustness, integration with a broader sensor suite and the dimensions and energy demands of the pressure supply require further evaluation. The researchers propose extending the approach to more complex musculoskeletal machines while combining it with minimal electronic control. Any claim about household, medical or industrial deployment would be premature.
Why this may interest engineers outside robotics
Mechanical feedback is an engineering design principle as much as a robotics story. When a physical component performs a response directly, designers may be able to simplify selected layers of sensing or control. Whether that reduces cost, improves safety or makes devices easier to maintain depends on the application and must be established by testing. The experiment therefore matters to researchers exploring compliant machines, low-computation control and future human-interacting devices—without proving that such products are ready for use.
The intriguing question: smarter software or smarter bodies?
The long trajectory of artificial intelligence has focused attention on more processing power and sophisticated algorithms. Living creatures suggest another source of capability: structure that already knows how to respond to force. Tohoku's robot offers a small but tangible illustration. Part of a step can emerge from the relationship between artificial muscles and the mechanical environment, with computers supervising rather than micromanaging every contraction. The project is still experimental. Its larger invitation is to reconsider how much intelligence can be placed in a machine's body.
Sources and verification
Sources checked October 24, 2026. The reported walking demonstration took place on a treadmill; simple electronic foot-contact control remained. No measured whole-system energy savings or independently reported field performance were established. No original interviews were conducted.